
News and Announcements
New IEEE Internet of Things Journal article
November 20, 2026
Our article Stabilizing Asynchronous Decentralized Federated Learning via Representation Decoupling has been accepted for publication in IEEE Internet of Things Journal. Federated learning (FL) enables collaborative model training across distributed devices without sharing raw data. However, most existing FL frameworks rely on centralized coordination or strict synchronization, which limits their applicability in highly dynamic and decentralized Internet-of-Things environments. In fully asynchronous decentralized FL (DFL), exchanging complete models across heterogeneous devices can destabilize training, particularly under data imbalance, where device-specific classifiers diverge and disturb shared representation learning. In this work, we identify that the tight coupling between representation backbones and local classifiers is a key source of instability in asynchronous DFL. We propose a backbone–head decoupling framework that separates transferable feature extractors from device-specific prediction heads. Devices exchange only backbone parameters while training personalized heads locally. This structural separation mitigates cross-device interference from distribution-sensitive classifiers, stabilizes asynchronous updates, and also preserves personalization. Extensive experiments under diverse system dynamics and heterogeneous data distributions demonstrate that the proposed framework stabilizes asynchronous DFL, consistently improves personalization accuracy by over 10% in challenging scenarios, and maintains strong backbone generalization.
(link to more information)New IEEE Transactions on Vehicular Technology article
November 14, 2026
Our article Modeling and Optimization of Vehicular-Enhanced Urban RANs with In-Band Backhaul has been accepted for publication in IEEE Transactions on Vehicular Technology. Ground and aerial vehicles offer interesting opportunities for the dynamic deployment of small cell base stations (BSs) to complement static BS infrastructure in Beyond-5G and 6G networks. This enables a form of adaptive network densification that holds the potential to decrease infrastructure and operational costs. While previous studies provide insights into the feasibility of vehicular-enhanced RANs, they largely overlook the issue of determining in which conditions such adaptive densification provides a more efficient alternative to fully static (and often overprovisioned) deployments, particularly when accounting for the resource cost of wireless backhauling. The present work addresses this problem by proposing an analytical framework based on stochastic geometry to model vehicular-enhanced RANs that integrate static BSs with moving small cell BSs with in-band integrated access and backhaul. Our framework enables the assessment of the resource gains achievable through optimal provisioning of vehicular-enhanced RANs, via a joint optimization (in terms of capital expenditure and consumed energy) of deployment and resource allocation under QoS constraints, while accounting for road-grid mobility patterns and the complex interactions between access and backhaul links. Numerical assessment shows that our approach provides novel key insights on the conditions under which the dynamic network densification enabled by vehicle-based base stations can significantly reduce both operational and capital RAN costs.
(link to more information)New DFG project ResCCTC
November 11, 2026
Our proposal Enhancing Resilience in Wireless Networks with Network Coding and Cross-Technology Communication (ResCCTC) has been accepted for funding by the German research foundation DFG. Building upon prior work on cross-technology communication (CTC) as well as the use of network coding (NC), we plan to explore how these two technologies can complement each other to increase the resilience of wireless networks.
(link to more information)New BMFTR project SIX-BRICC
November 02, 2026
We are happy to be part of SIX-BRICC - 6G-in-a-Box for Resilient Incident Critical Communication. In this project, we will explore a resilient mobile 6G-in-a-Box system for emergency medical operations.
(link to more information)Poster at MobiCom AI-RAN Workshop 2026
October 30, 2026
Our team member Osman Tugay Basaran presented our research at the 32th ACM International Conference on Mobile Computing and Networking (MobiCom 2026) in Austin, Texas, during the 3rd ACM Workshop on Open and AI-RAN. Our paper, "VeriRAN: Explainable and Runtime-Verified Multi-Agent Control for Trustworthy AI-RAN", introduces a GPU-accelerated framework that combines parallel multi-agent control loops with formal runtime verification to enforce deterministic safety guardrails in real-time radio access networks.
(link to more information)Demo at MobiCom 2026
October 29, 2026
Our team member Christos Laskos presented a live demonstration at 30th ACM International Conference on Mobile Computing and Networking (MobiCom 2026) in Austin, Texas; connected to the TU Berlin laboratory, where team member Joana Angjo operated the experimental setup. The demo, "Now You See It! RIS-Assisted mmWave Radar for NLOS Sensing", showed how a reconfigurable intelligent surface (RIS) can redirect 28 GHz radar signals around an obstruction to detect a target outside the radar’s direct line of sight.
(link to more information)Paper Presentation at MSWiM 2026
October 28, 2026
Atefeh Rezaei presented our paper “Mobility-Aware Interference-Coupled ISAC for Energy-Efficient Multi-Vehicle Tracking” at the 28th IEEE International Conference on Modeling, Analysis and Simulation of Wireless and Mobile Systems (MSWiM 2026) in Paris, France. This work proposes a mobility-aware integrated sensing and communications (ISAC) framework for millimeter-wave vehicle-to-infrastructure networks that leverages multi-vehicle tracking to enable predictive beamforming.
(link to more information)New IEEE Internet of Things Journal article
October 27, 2026
Our article AoI-FusionNet: Age-Aware Tightly Coupled Fusion of UWB-IMU under Sparse Ranging Conditions has been accepted for publication in IEEE Internet of Things Journal. Accurate motion tracking of snow particles in avalanche events requires robust localization in global navigation satellite system (GNSS)-denied outdoor environments. This paper introduces AoI-FusionNet, a tightly coupled deep-learning-based fusion framework that directly combines raw ultra-wideband (UWB) time of flight (ToF) measurements with inertial measurement unit (IMU) data for 3D trajectory estimation. Unlike loose-coupled pipelines based on intermediate trilateration, the proposed approach operates directly on heterogeneous sensor inputs, thereby enabling localization even under insufficient ranging availability. This framework integrates an age of information (AoI)-aware decay module to reduce the influence of stale UWB range measurements and a learned attention gate mechanism that adaptively balances trust between UWB and IMU modalities as a function of measurement availability and temporal freshness. To evaluate performance under limited training data and measurement variability, a diffusion-based residual augmentation strategy is applied during training, producing an augmented variant termed AoI-FusionNet-DGAN. Performance of the proposed model is assessed using offline post-processing of real-world measurement data from an alpine environment and benchmarked against geometric, model-based, learning-based, and tightly coupled UWB-IMU fusion baselines.The results demonstrate that AoI-FusionNet substantially reduces mean and tail localization errors under intermittent and degraded sensing conditions.
(link to more information)Keynote at 6G Resilience Summit 2026
October 27, 2026
Falko Dressler gave a keynote titled Communication and Computing for Resilient 6G Networks at the 6G Resilience Summit 2026.
(link to more information)New IEEE Transactions on Mobile Computing article
October 08, 2026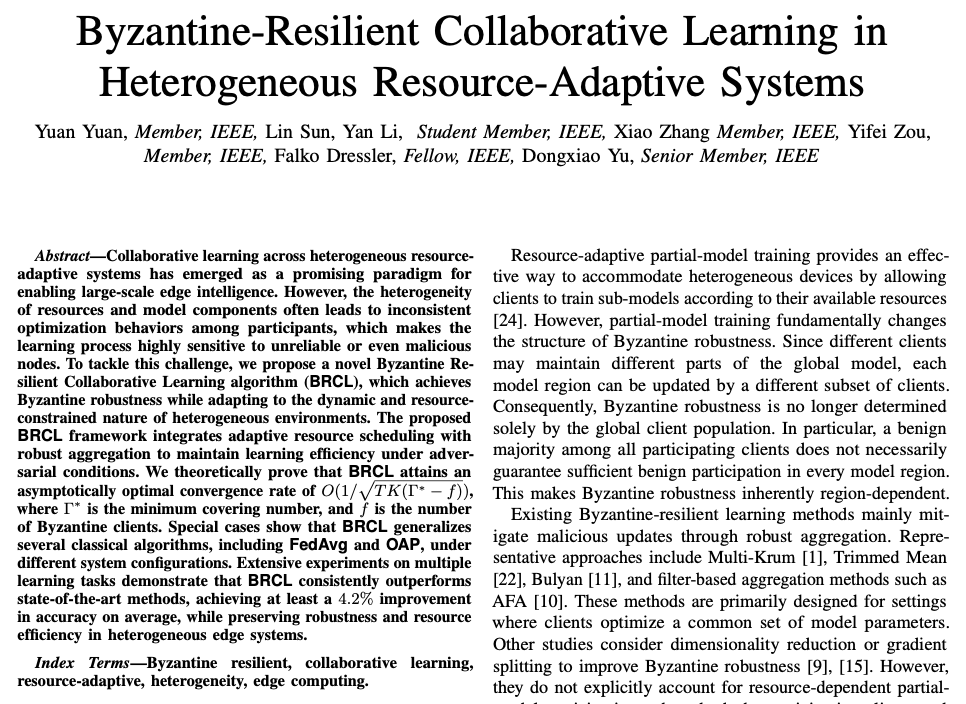
Our article Byzantine-Resilient Collaborative Learning in Heterogeneous Resource-Adaptive Systems has been accepted for publication in IEEE Transactions on Mobile Computing. Collaborative learning across heterogeneous resource-adaptive systems has emerged as a promising paradigm for enabling large-scale edge intelligence. However, the heterogeneity of resources and model components often leads to inconsistent optimization behaviors among participants, which makes the learning process highly sensitive to unreliable or even malicious nodes. To tackle this challenge, we propose a novel Byzantine Resilient Collaborative Learning algorithm (BRCL), which achieves Byzantine robustness while adapting to the dynamic and resource-constrained nature of heterogeneous environments. The proposed BRCL framework integrates adaptive resource scheduling with robust aggregation to maintain learning efficiency under adversarial conditions. We theoretically prove the asymptotically optimal convergence rate. Extensive experiments on multiple learning tasks demonstrate that BRCL consistently outperforms state-of-the-art methods, achieving at least a 4.2% improvement in accuracy on average, while preserving robustness and resource efficiency in heterogeneous edge systems.
(link to more information)
Load all older news
Last modified: 2024-04-28
TKN is co-organizing
Featured Paper
News
Featured Paper
- Stabilizing Asynchronous Decentralized Federated Learning via Representation Decoupling

Federated learning (FL) enables collaborative model training across distributed devices without sharing raw data. However, most existing FL frameworks rely on centrali...
News
- November 20, 2026
New IEEE Internet of Things Journal article
Our article Stabilizing Asynchronous Decentralized Federa... - November 14, 2026
New IEEE Transactions on Vehicular Technology article
Our article Modeling and Optimization of Vehicular-Enhanc... - November 11, 2026
New DFG project ResCCTC
Our proposal Enhancing Resilience in Wireless Networks wi... - November 02, 2026
New BMFTR project SIX-BRICC
We are happy to be part of SIX-BRICC - 6G-in-a-Box for Re... - October 30, 2026
Poster at MobiCom AI-RAN Workshop 2026
Our team member Osman Tugay Basaran presented our researc...